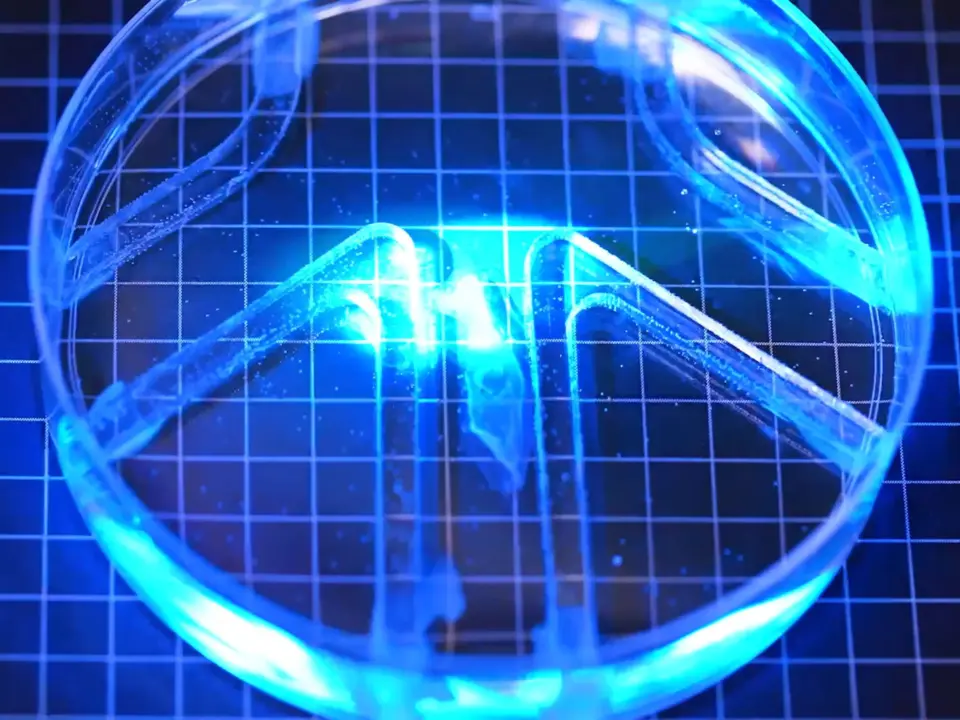
MIT researchers have introduced Aquabot, a prototype biohybrid robot that uses living muscle tissue for movement. This development matters because it demonstrates a new way to build tiny machines that can navigate complex environments without traditional motors or batteries. The approach opens potential pathways for future medical and environmental tools that operate inside living systems.
Light-controlled muscle tissue drives ultra-thin prototype
The device is a two-dimensional gel layer roughly the size of a stick of chewing gum. MIT describes the Aquabot as an ultra-thin robot that moves on its own while remaining significantly smaller than previous muscle-powered models. It swims through water using fins attached along its two edges to generate propulsion.
Specifications
- Dimensions: Roughly the length and width of a stick of chewing gum
- Max Speed: Four body lengths per minute
- Power Source: Genetically modified living muscle cells responding to light
- Structure: Ultra-thin, two-dimensional gel layer with fins
Power comes from genetically modified living muscle cells embedded in the gel. When researchers illuminate specific parts of the robot, the muscle cells contract. Turning off the light allows the layer to relax. This light-based control lets operators steer the device by selectively lighting its fins.
The robot moves at a maximum speed of four body lengths per minute. MIT notes this pace is comparable to that of a sixgill shark. The team suggests this technology could eventually support environmental monitoring or internal human body exploration. No pricing or release date is available for this research prototype.
Aquabot represents a shift toward smaller, bio-integrated hardware designs. The prototype confirms that light-controlled muscle tissue can drive movement in ultra-thin structures. Researchers continue to explore how this mechanism might scale for practical applications.
Source: NotebookCheck
Discussion
0 comments